Hardware
Scanning Rover
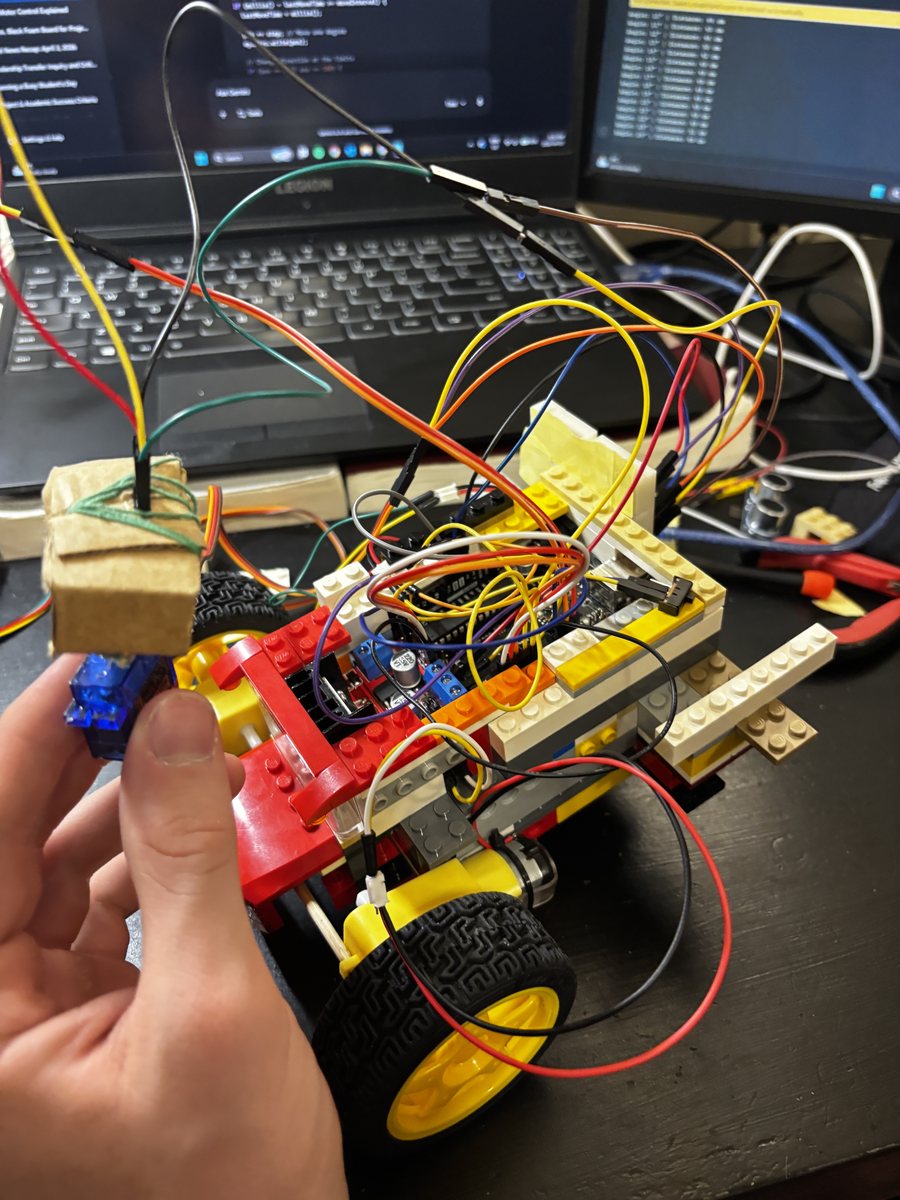
An Arduino rover that checks three directions with an ultrasonic sensor and drives toward the most open one.
What it does
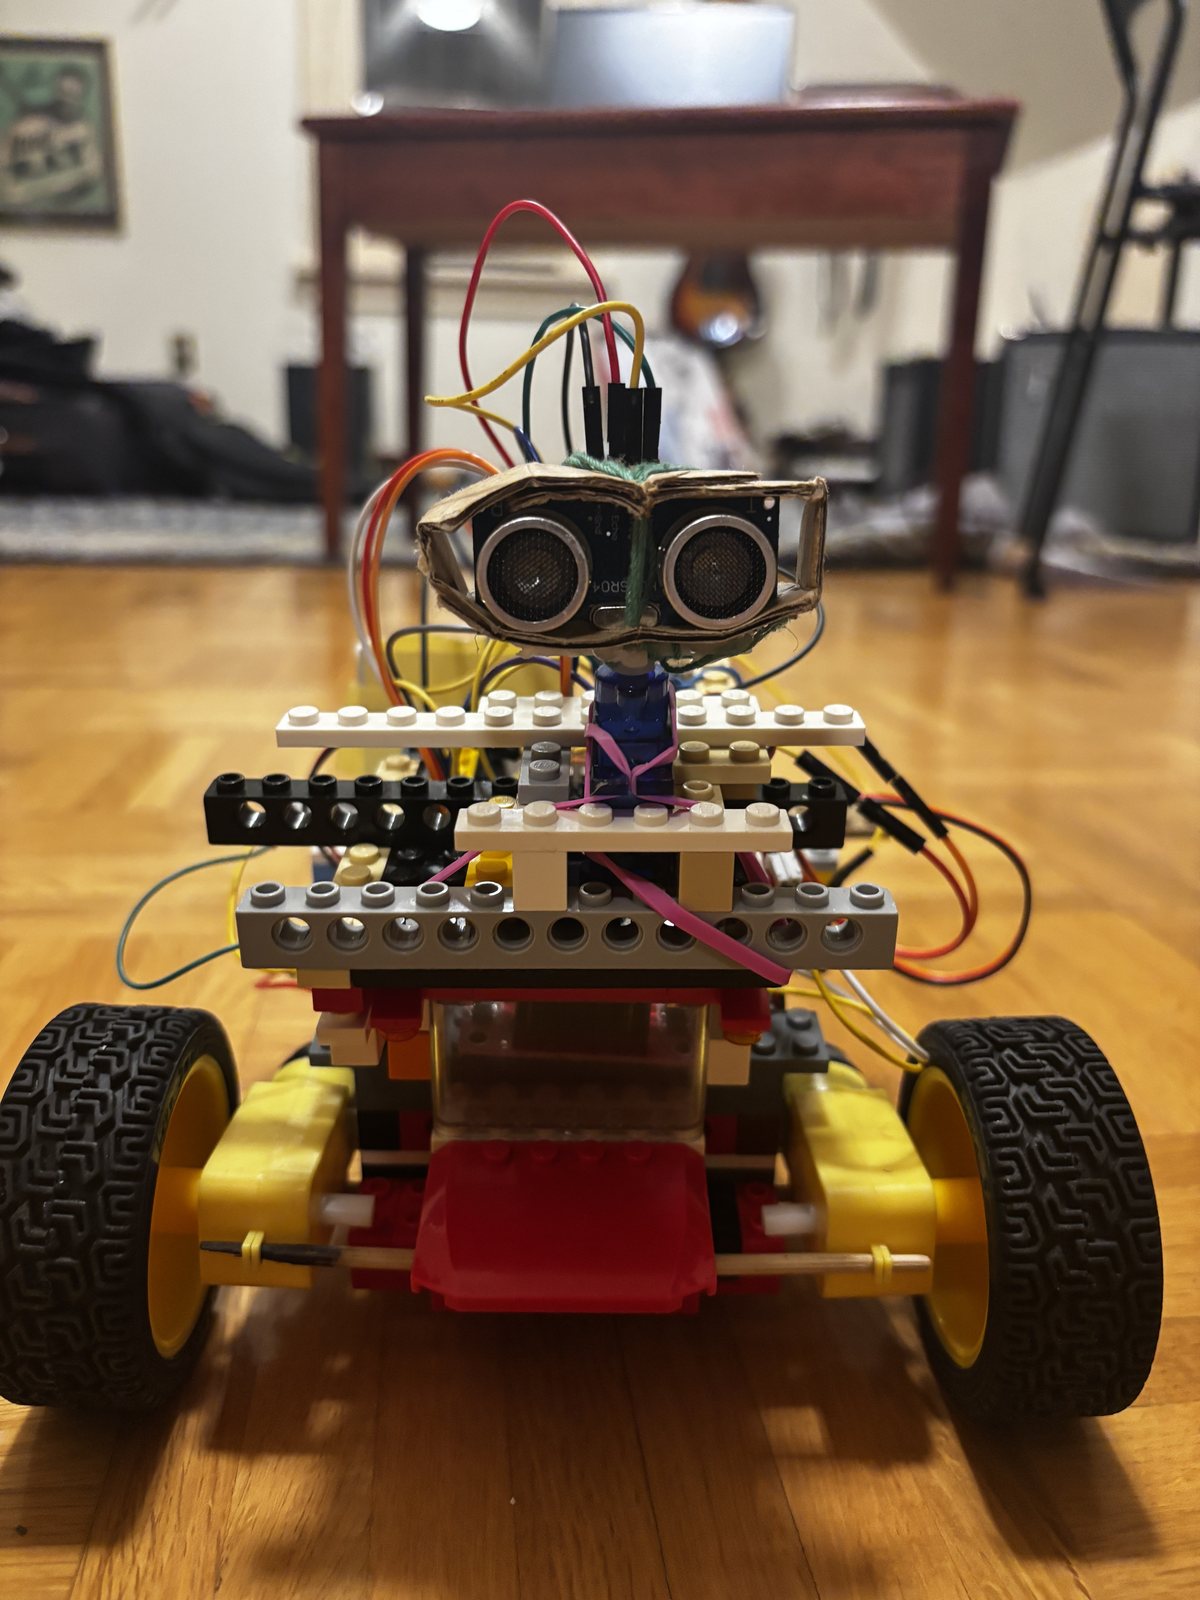
Before every move, a servo turns the sensor left, center and right, and the rover drives toward whichever way has the most room. Three readings is the fewest that let it pick a direction instead of only reacting to what's straight ahead.
Technical details
- Controller
- Arduino UNO
- Sensing
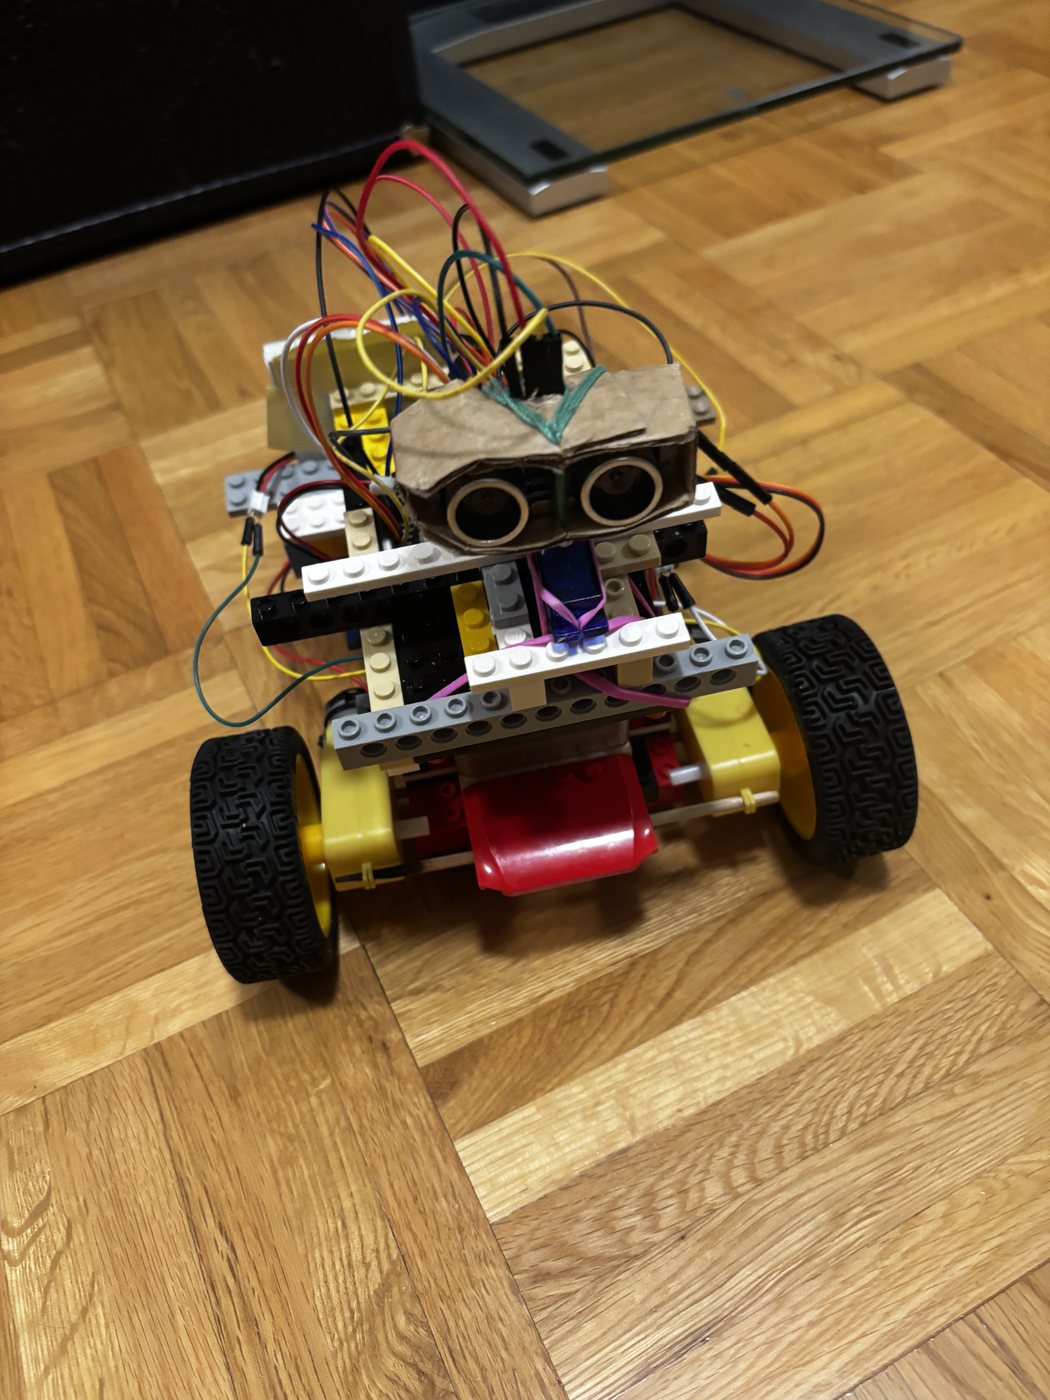
- HC-SR04 ultrasonic rangefinder on an SG90 servo
- Drive
- Two TT gearmotors, an L298N H-bridge and a LEGO Technic chassis
- Control loop
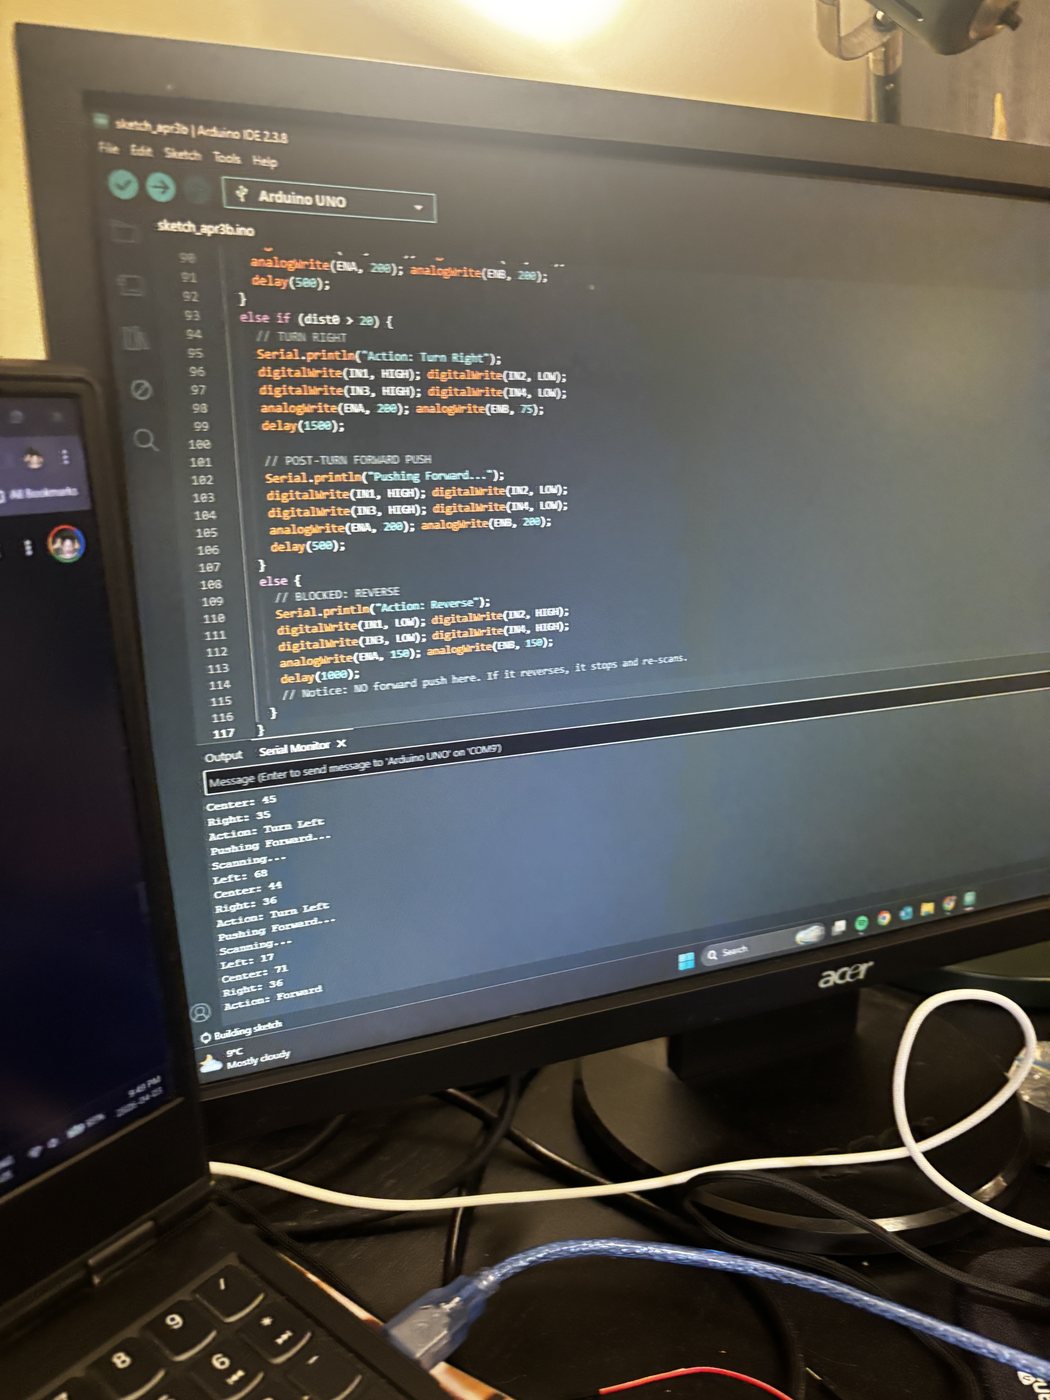
- It scans three headings, measures the distance at each and steers toward the one with the most clearance.
- Recovery
- When it's blocked it reverses, stops and scans again before moving.
Engineering decisions
The sensor only looks forward, so the steering has to protect the back of the rover. It turns in arcs, with both wheels running at different speeds through PWM, instead of pivoting on one wheel. The tail sweeps a wider path and stays clear of whatever the rover just turned away from.